Skip to content
@NVIDIA-ISAAC-ROS

NVIDIA Isaac ROS

High-performance computing for robotics built on ROS 2

NVIDIA Isaac ROS

image

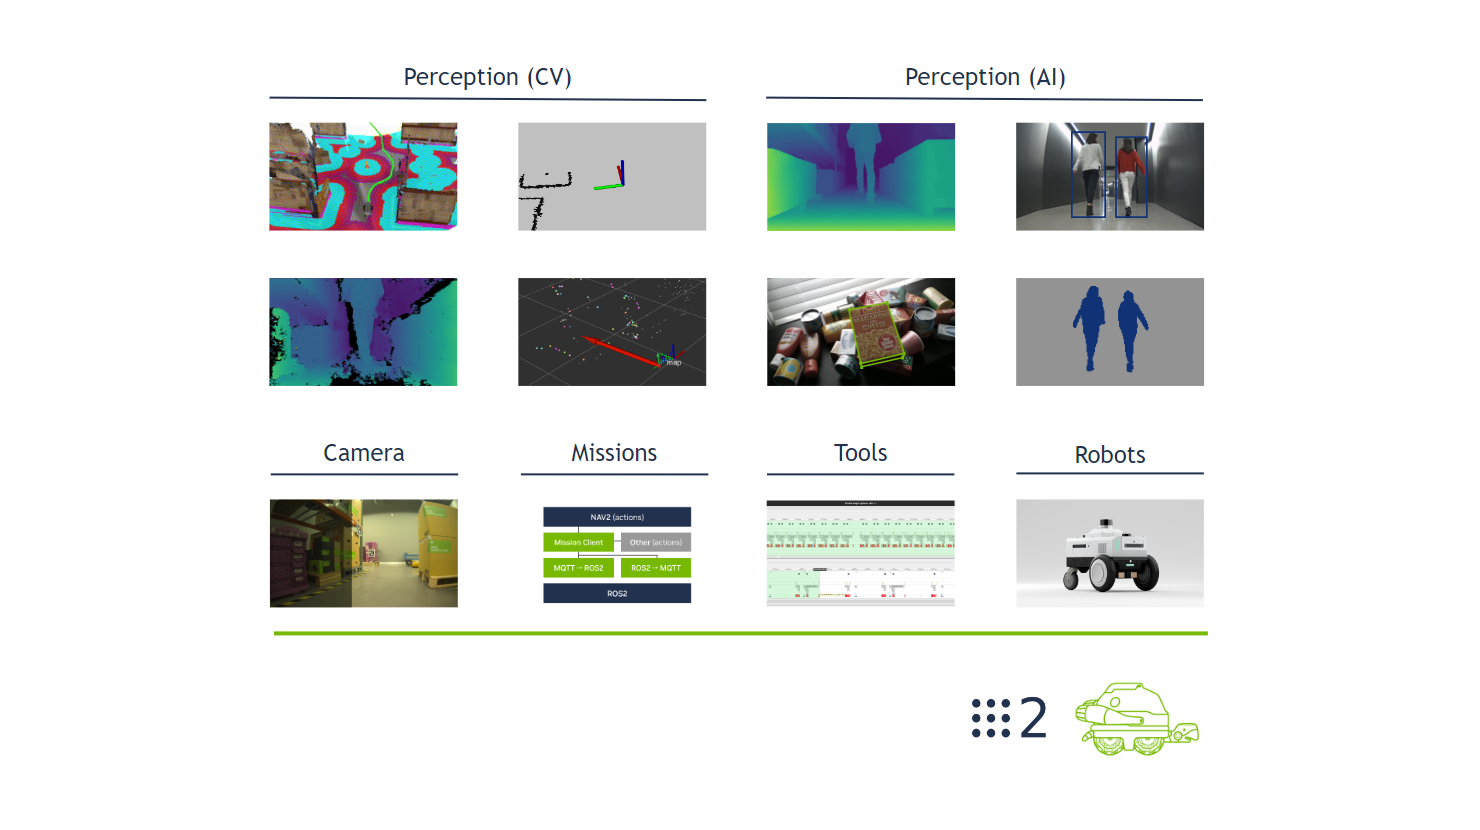
Welcome to Isaac ROS, a collection of NVIDIA-accelerated, high performance, low latency ROS 2 packages for making autonomous robots which leverage the power of Jetson and other NVIDIA platforms.

  • Check out the getting started to start using Isaac ROS.
  • Visit the repositories and packages to learn about specific packages.
  • Familiarize yourself with concepts essential to Isaac ROS.
  • Compare the performance of the packages on various platforms.
  • Read the collection of blog posts for more information.
  • Scan through the FAQs for answers to common questions.
  • Reference the release notes for details on all updates made to Isaac ROS.

Pinned Loading

  1. isaac_ros_manipulation isaac_ros_manipulation Public

    Arm manipulation workflows

    C++ 114 25

  2. isaac_ros_dnn_stereo_depth isaac_ros_dnn_stereo_depth Public

    NVIDIA-accelerated, deep learned stereo disparity estimation

    C++ 156 16

  3. isaac_ros_image_segmentation isaac_ros_image_segmentation Public

    NVIDIA-accelerated, deep learned semantic image segmentation

    C++ 127 16

  4. isaac_ros_pose_estimation isaac_ros_pose_estimation Public

    Deep learned, NVIDIA-accelerated 3D object pose estimation

    C++ 502 57

  5. greenwave_monitor greenwave_monitor Public

    ROS 2 Topic Monitoring

    Python 233 19

  6. isaac-ros-cli isaac-ros-cli Public

    A command-line interface for managing Isaac ROS development environments.

    Python 10 15

Repositories

Showing 10 of 66 repositories
  • sensor_mounting_rig Public

    URDF and other files associated with hardware mounting of sensors onto Jetson Developer Kits

    NVIDIA-ISAAC-ROS/sensor_mounting_rig's past year of commit activity
    Python 3 3 0 0 Updated Sep 22, 2026
  • ros2_benchmark Public

    Benchmark the performance of your ROS 2 graphs

    NVIDIA-ISAAC-ROS/ros2_benchmark's past year of commit activity
    Python 142 Apache-2.0 18 1 1 Updated Sep 22, 2026
  • isaac_ros_visual_slam Public

    Visual SLAM/odometry package based on NVIDIA-accelerated cuVSLAM

    NVIDIA-ISAAC-ROS/isaac_ros_visual_slam's past year of commit activity
    C++ 1,473 Apache-2.0 206 73 (1 issue needs help) 4 Updated Sep 22, 2026
  • isaac_ros_teleop Public

    Teleoperation Solutions using XR headsets.

    NVIDIA-ISAAC-ROS/isaac_ros_teleop's past year of commit activity
    C++ 3 Apache-2.0 4 0 0 Updated Sep 22, 2026
  • isaac_ros_sipl_camera Public

    NVIDIA-accelerated ROS 2 camera drivers on Jetson via Nvidia Sensor Input Processing Library (SIPL) cameras framework

    NVIDIA-ISAAC-ROS/isaac_ros_sipl_camera's past year of commit activity
    C++ 3 Apache-2.0 3 0 0 Updated Sep 22, 2026
  • isaac_ros_robots Public

    Support packages for robots

    NVIDIA-ISAAC-ROS/isaac_ros_robots's past year of commit activity
    C++ 0 Apache-2.0 2 0 0 Updated Sep 22, 2026
  • isaac_ros_pose_estimation Public

    Deep learned, NVIDIA-accelerated 3D object pose estimation

    NVIDIA-ISAAC-ROS/isaac_ros_pose_estimation's past year of commit activity
    C++ 502 Apache-2.0 57 38 6 Updated Sep 22, 2026
  • isaac_ros_physical_ai Public

    Application-level bringup packages for deploying whole-body control and teleoperation on humanoid robots

    NVIDIA-ISAAC-ROS/isaac_ros_physical_ai's past year of commit activity
    CMake 2 Apache-2.0 3 0 0 Updated Sep 22, 2026
  • isaac_ros_object_detection Public

    NVIDIA-accelerated, deep learned model support for image space object detection

    NVIDIA-ISAAC-ROS/isaac_ros_object_detection's past year of commit activity
    C++ 202 Apache-2.0 51 13 4 Updated Sep 22, 2026
  • isaac_ros_nvblox Public

    NVIDIA-accelerated 3D scene reconstruction and Nav2 local costmap provider using nvblox

    NVIDIA-ISAAC-ROS/isaac_ros_nvblox's past year of commit activity
    C++ 752 Apache-2.0 142 48 7 Updated Sep 22, 2026

People

This organization has no public members. You must be a member to see who’s a part of this organization.